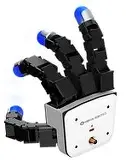
Key benefits
- Dexterous 4-finger kinematics: 3 fingers + thumb with 16 independently controlled joints.
- Torque (current) control: supports compliant grasps and modern manipulation control strategies.
- 360° tactile sensing at the fingertips: pressure-aware manipulation for rigid and deformable objects.
- Real-time CAN interface: listed control/communication frequency 500 Hz.
- High payload rating: up to 15 kg (measurement-method dependent).
Fingers4 (incl. thumb)
Active DoF16
CommsCAN (500 Hz)
Power24 V / 120 W
Payload and achievable performance depend on grasp type, object geometry, friction, and test method. Validate for your specific application.
Technical Hardware Specifications
Core specifications (V5 Plus / 4F)
| Specification |
Value |
| Hand configuration |
4 fingers (3 fingers + 1 thumb) |
| Active degrees of freedom (DoF) |
16 (4 fingers × 4) |
| Actuation type |
DC motor |
| Communication |
CAN |
| Control / communication frequency |
500 Hz (CAN) |
| Power requirement |
24.0 V / 5.0 A / 120 W |
| Payload |
15 kg (depending on measurement method) |
| Joint resolution |
0.088° |
| Weight (manufacturer) |
1,024 g |
| Item weight (shop listing, may include cabling/packaging variance) |
~1.20 kg |
Actuation & torque
| Specification |
Value |
| Gear ratio |
288.35:1 (typical)
576.7:1 (2nd joint of the finger, excluding the thumb) |
| Stall torque |
0.92 N·m (typical)
1.84 N·m (2nd joint of the finger, excluding the thumb) |
| Nominal torque |
0.23 N·m (typical)
0.46 N·m (2nd joint of the finger, excluding the thumb) |
Specifications can vary by revision and configuration. Always confirm the latest manufacturer documentation for your exact unit.
Fingertip Pressure Sensor (360° tactile sensing)
- 360° omnidirectional pneumatic tactile sensing designed to detect pressure at the fingertips.
- Air pressure measurement using a capacitive pressure sensor.
- Human-finger-like stiffness for natural contact behavior.
- Color changes based on tactile sensitivity (visual feedback).
- Pressure range (listed): up to ~24,000 Pa (with bands shown in documentation).
Fingertip types
| Type |
Purpose / characteristics |
| Type A (Default) |
Internal support structure under silicone surface for a firm, stable grip. |
| Type B |
External support structure; suited for delicate object gripping. |
| Type C |
Shorter sensor; sensing concentrated near the top for stronger, more precise gripping. |
| Type D |
Wide back support structure for strong lateral gripping. |
Fingertip options may be configurable depending on supplier package.
Software & workflow (typical)
- Near real-time visualization in RViz2
- Custom pose storage and execution with MoveIt 2
- Convenient control via a GUI (pose generation + motion control)
Scope of delivery (typical kit)
- Allegro Hand V5 Plus
- Control and communication modules
- Power supply
- Cable set
- Software and documentation
- Mechanical accessories
Contents can vary by supplier and package—confirm exact scope before ordering.
FAQ
What is the main advantage of the V5 Plus (4F) vs. a 3-finger hand?
The additional finger and higher DoF enable more stable grasps and richer in-hand manipulation, especially when combined with tactile feedback.
Is this suitable for real-time research control?
Yes—CAN communication is listed with a 500 Hz frequency, supporting real-time manipulation workflows.
How do I choose the fingertip type?
Choose based on your target objects: Type B for fragile items, Type D for lateral grips, Type C for stronger top-focused contact, and Type A as the general-purpose default.